Electrical & Embedded Developer
Kelpie Robotics
Designed and assembled the sensor board for the University of Ottawa’s underwater robotics competition team.
Overview
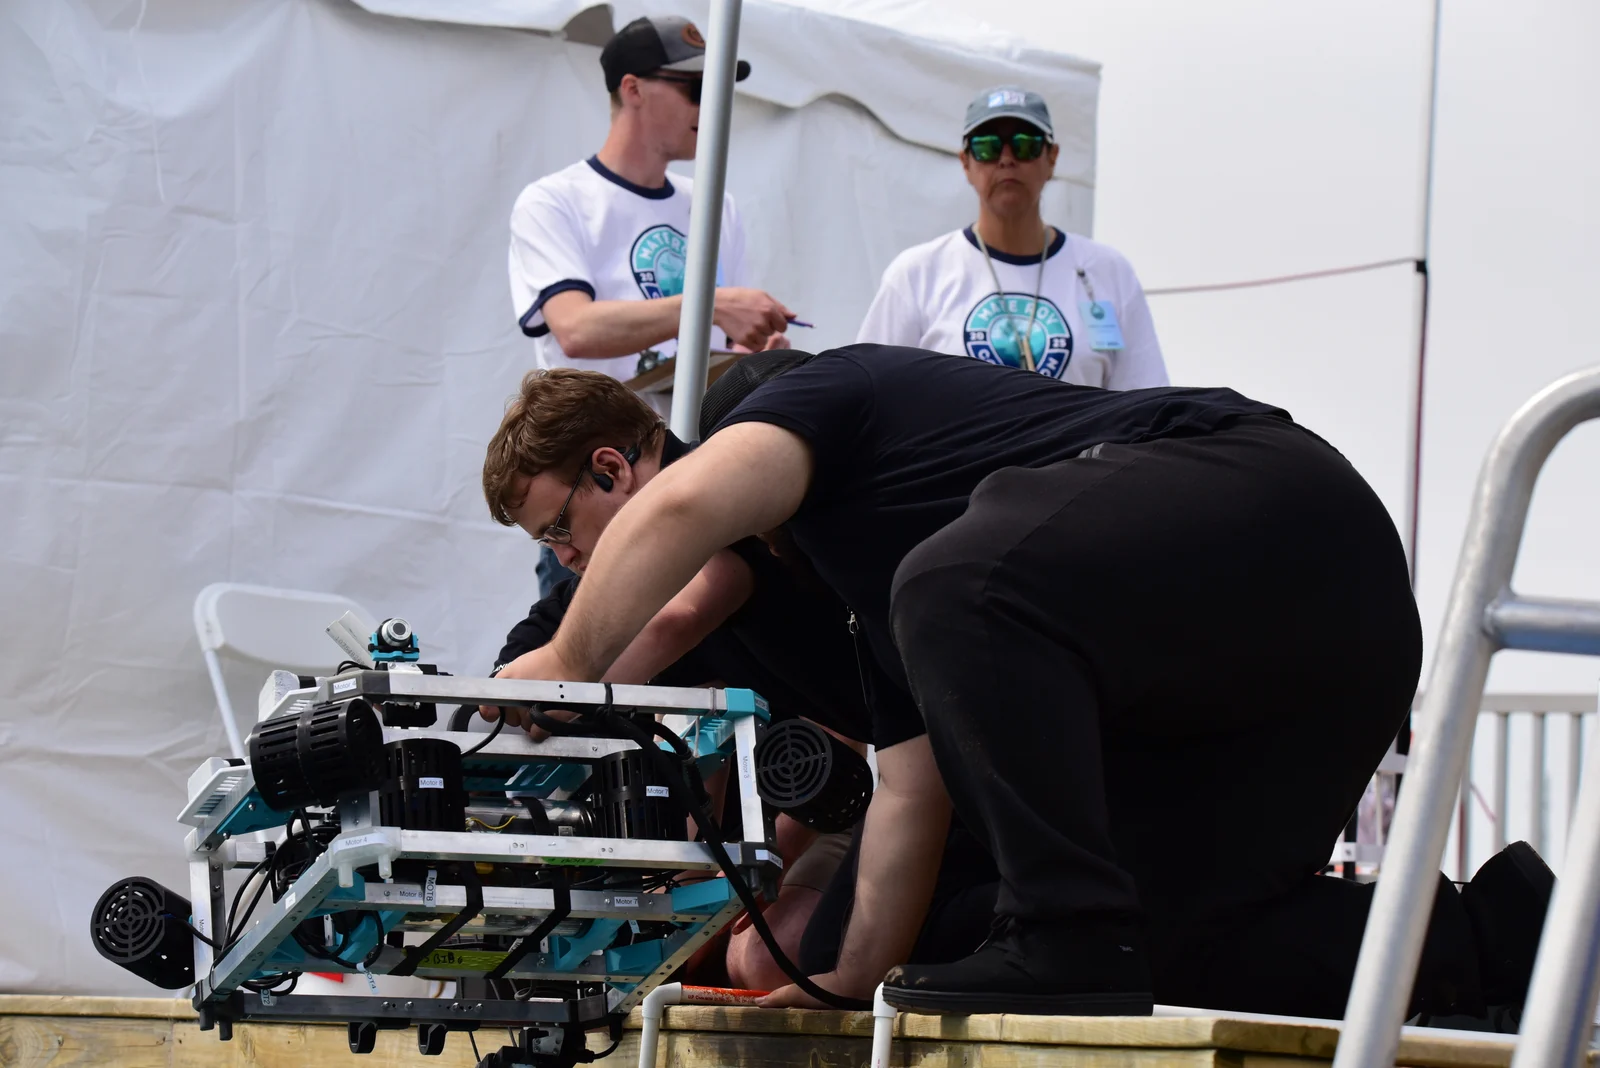
Designed and assembled the sensor board in KiCad for SELK-I, the team’s underwater robot: it takes the power inputs and connects a Raspberry Pi and a Pixhawk flight controller to sensors such as leak detectors.
Integrated the electronics with the robot’s embedded and mechanical subsystems, on a team of about 20.
Skills
- EDA
- PCBA
- KiCad
- Embedded systems
- Underwater robotics
- Raspberry Pi
- Pixhawk
Photos6